Template
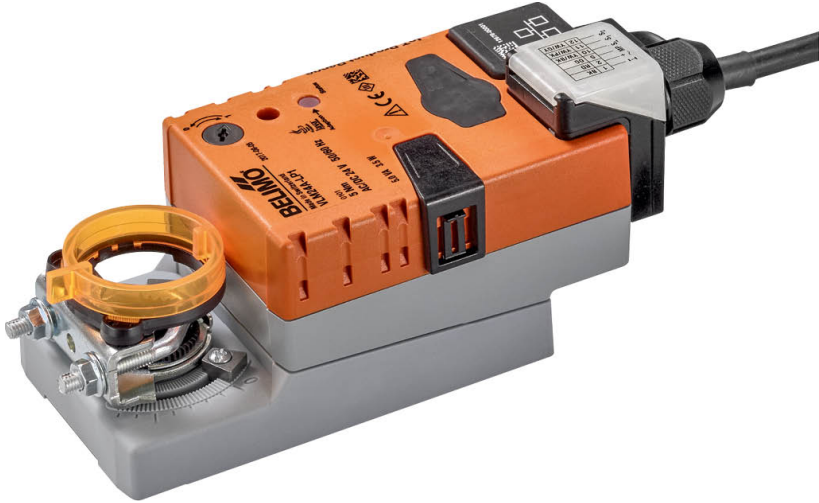
Belimo IoT Actuator Modbus TCP
Content languageEnglish
Description
The actuator is controlled via the Cloud, BACnet IP or Modbus TCP and drives to the position defined by the control signal. Various data points can be written and read via the same interfaces. Hybrid mode: The actuator receives its analog control signal from the higher level controller and drives to the position defined. Using the Cloud, BACnet IP or Modbus TCP, various data points can be read and with the exception of the control signal written.
Structure:
Inputs and outputs · 16
| Name | Type | Unit |
|---|---|---|
| Actuator Type | Modbus | <v> |
| Relative Position | Modbus | % |
| Absolute Position | Modbus | ° |
| Sensor 1 Value | Modbus | <v.1> |
| Setpoint Analog | Modbus | % |
| Series Number 1st Part | Modbus | <v> |
| Series Number 2nd Part | Modbus | <v> |
| Series Number 4th Part | Modbus | <v> |
| Firmware Version | Modbus | <v> |
| Malfunction and Service Information | Modbus | <v> |
| Sensor 2 Value | Modbus | <v.1> |
| Setpoint | Modbus | % |
| Override Control | Modbus | <v> |
| Sensor 1 Type | Modbus | <v> |
| Setpoint Source | Modbus | <v> |
| Sensor 2 Type | Modbus | <v> |
Ratings and comments
No ratings or comments yet.
Log in to rate, comment or ask a question. Log in